Source: Times of India
Introduction
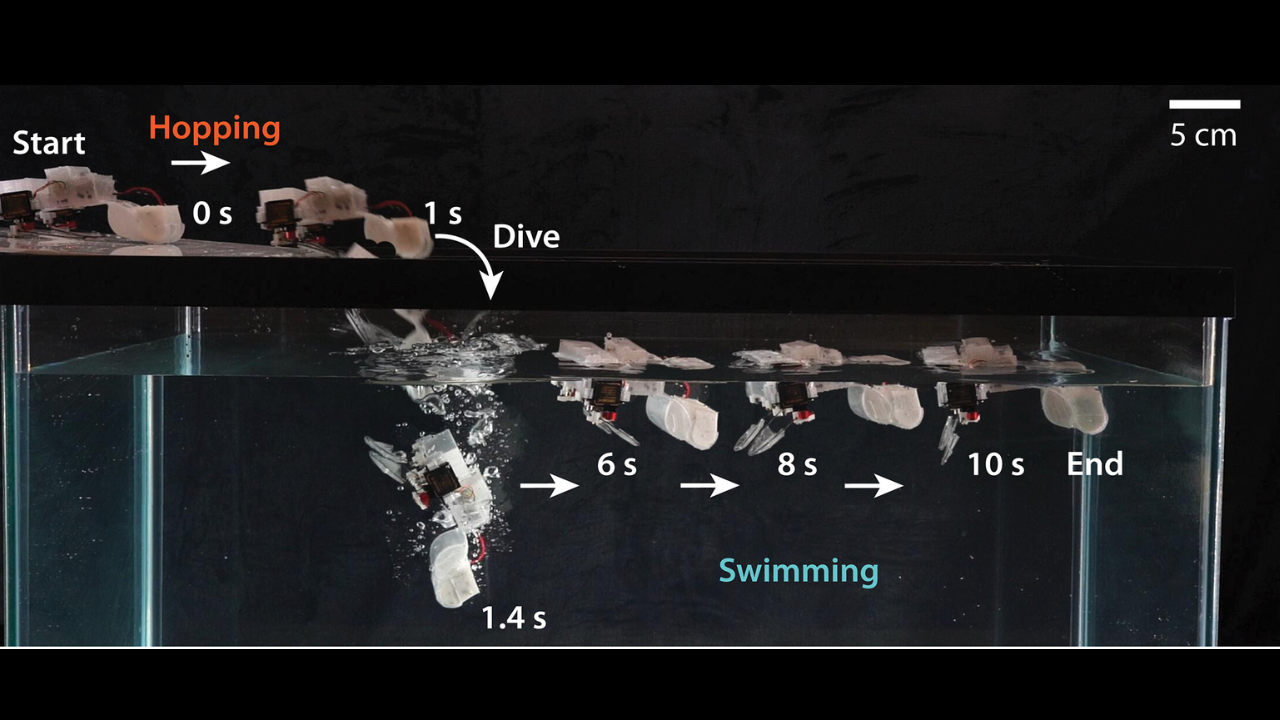
Robotics researchers have unveiled a groundbreaking 98-gram hopping robot, a compact machine engineered to navigate complex environments with unprecedented versatility. By utilizing a unique snapping elastic rod mechanism, this untethered device demonstrates the ability to traverse six distinct types of terrain while maintaining high-speed movement.
This development marks a significant shift in small-scale robotics, as the machine successfully combines land-based agility with aquatic performance. As engineers continue to push the boundaries of what portable hardware can achieve, this 98-gram hopping robot stands out for its efficiency and mechanical ingenuity in crossing challenging landscapes.
What Happened
The core innovation behind this device lies in its propulsion system, which replaces traditional motorized limbs with snapping elastic rods. When triggered, these rods release stored energy to propel the robot forward, allowing it to hop across uneven surfaces at speeds that exceed three body lengths per second.
Beyond its land-based capabilities, the robot is also designed to operate in water. The same elastic components that facilitate hopping on solid ground serve as a propulsion mechanism when submerged. By generating thrust through these specialized limbs, the robot achieves movement that surpasses the speed and efficiency typically associated with rigid-legged designs.
Background
Traditional small-scale robots have historically struggled with the transition between different environmental states, often requiring separate systems for land and water navigation. Many existing designs rely on rigid legs that are optimized for specific surfaces, which limits their utility when encountering diverse or unpredictable terrain.
The development of this new model addresses these limitations by utilizing a unified, energy-efficient mechanism. By focusing on the physics of elastic snapping rather than complex motorized joints, researchers have produced a lightweight, untethered platform that functions across a variety of settings without the need for frequent hardware adjustments.
Key Details
The robot’s design specifications highlight its performance metrics and physical characteristics. Its ability to operate across six terrains, combined with its specialized swimming mechanics, positions it as a highly adaptable tool for navigating complex environments.
| Feature | Specification/Capability |
|---|---|
| Weight | 98 grams |
| Movement Speed | Exceeds three body lengths per second |
| Operational Terrains | Six distinct terrains |
| Propulsion Mechanism | Snapping elastic rods |
| Aquatic Capability | Capable of swimming using elastic limbs |
| Power Configuration | Untethered |
Impact
The implications of this technology are centered on the efficiency and speed gains provided by the elastic-limb design. By outperforming rigid-legged alternatives, this robot offers a new blueprint for how small-scale devices might be constructed to handle multi-environment missions.
The ability to maintain consistent speed while transitioning from land to water is a notable achievement in the field of robotics. This design philosophy emphasizes mechanical efficiency, potentially reducing the weight and complexity of future untethered robots intended for versatile field operations.
What Happens Next
While the robot currently demonstrates robust capabilities across diverse terrains and aquatic environments, the underlying mechanism of snapping elastic rods remains the focal point for further observation. The integration of this lightweight, high-speed mobility system provides a foundational platform for future advancements in adaptive, small-scale robotic systems.
As the technology moves forward, the focus remains on the robot's ability to navigate environments effectively, leveraging its unique limb design to sustain its performance advantages over traditional robotic architectures. The successful testing of this 98-gram unit proves the viability of elastic propulsion for multi-terrain applications, setting the stage for broader integration into specialized robotic fields.